06 / Robotics · Embedded
Autonomous Obstacle-Avoidance Car
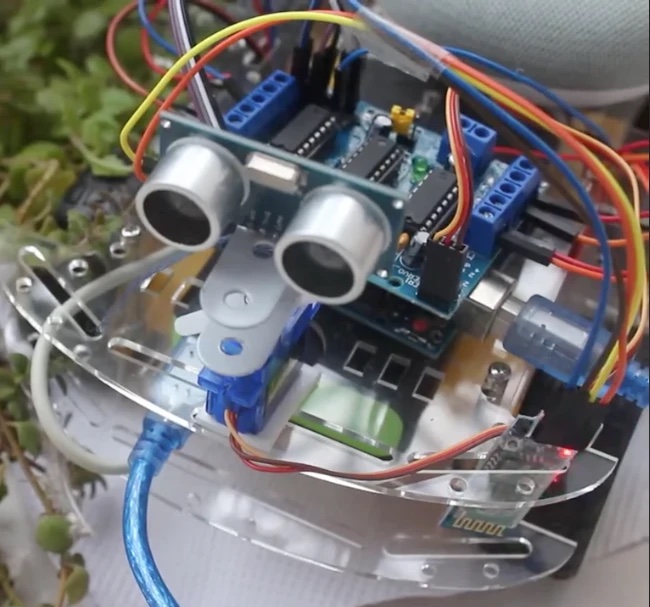
An autonomous car built on an Arduino Uno. It uses object-detection sensors to spot obstacles and steers around them on its own, and it can also be driven remotely from a custom app. Presented at Vision Engineering Fest.
Arduino Unomain controller
HC-SR04ultrasonic obstacle sensing
Servo mountlets the sensor look around
Bluetoothremote control via custom app
How it works
The car runs a simple sense → decide → act loop on the Arduino Uno:
- Sense: the HC-SR04 ultrasonic sensor measures the distance to whatever is in front of the car.
- Decide: when an obstacle comes too close, the car stops. The sensor sits on a servo, so it can turn to check the sides and find a clear direction.
- Act: the motor-driver shield drives the wheels to steer away from the obstacle and carry on, so the car moves smoothly without collisions.
Remote control
Besides driving itself, the car can be remote controlled from a custom app. A Bluetooth module on the chassis receives the commands from the app.